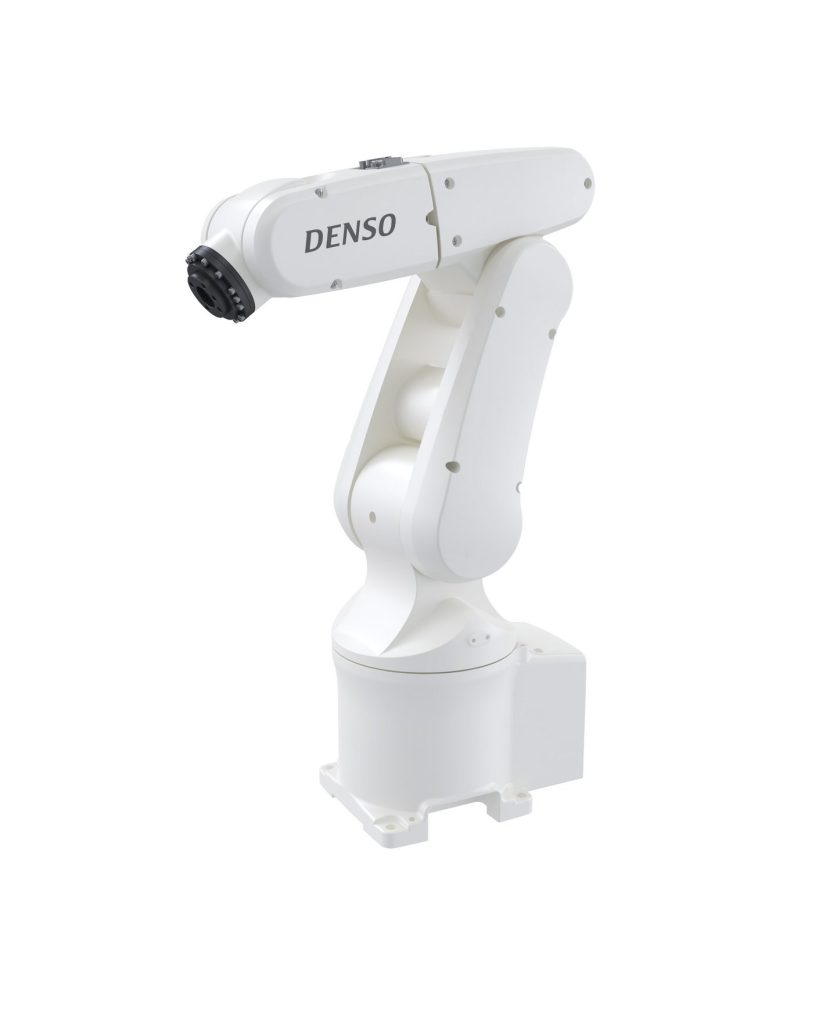
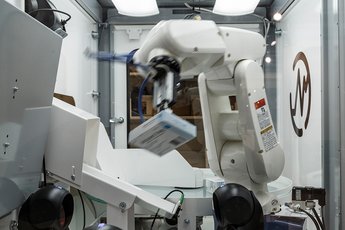
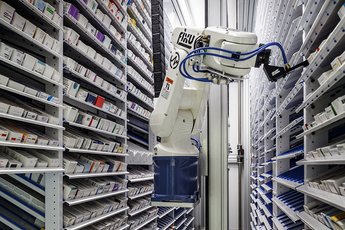
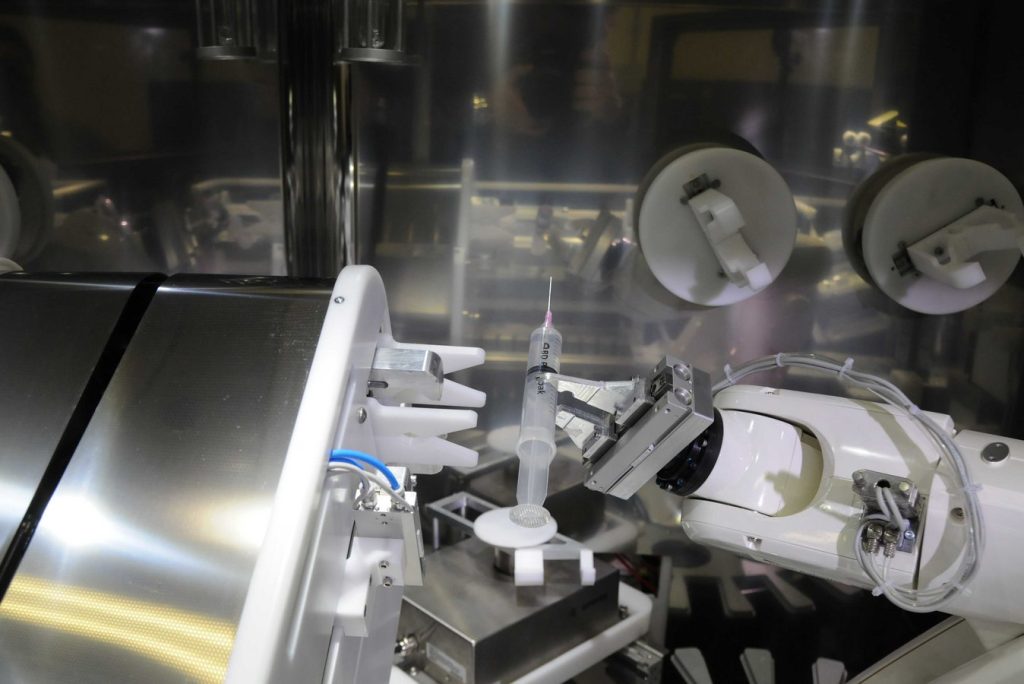
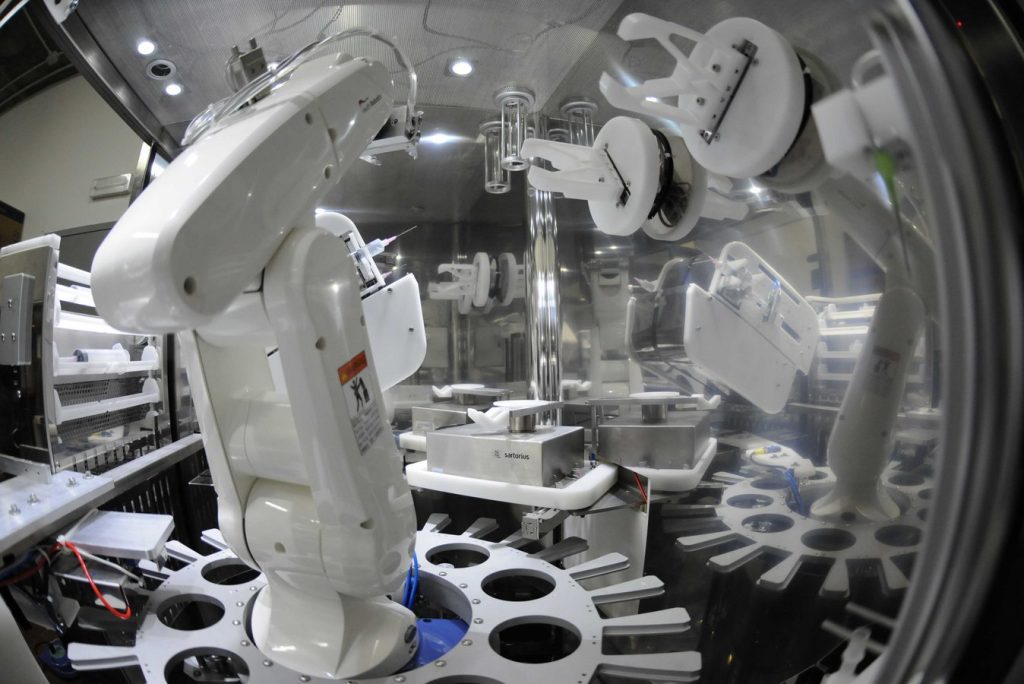
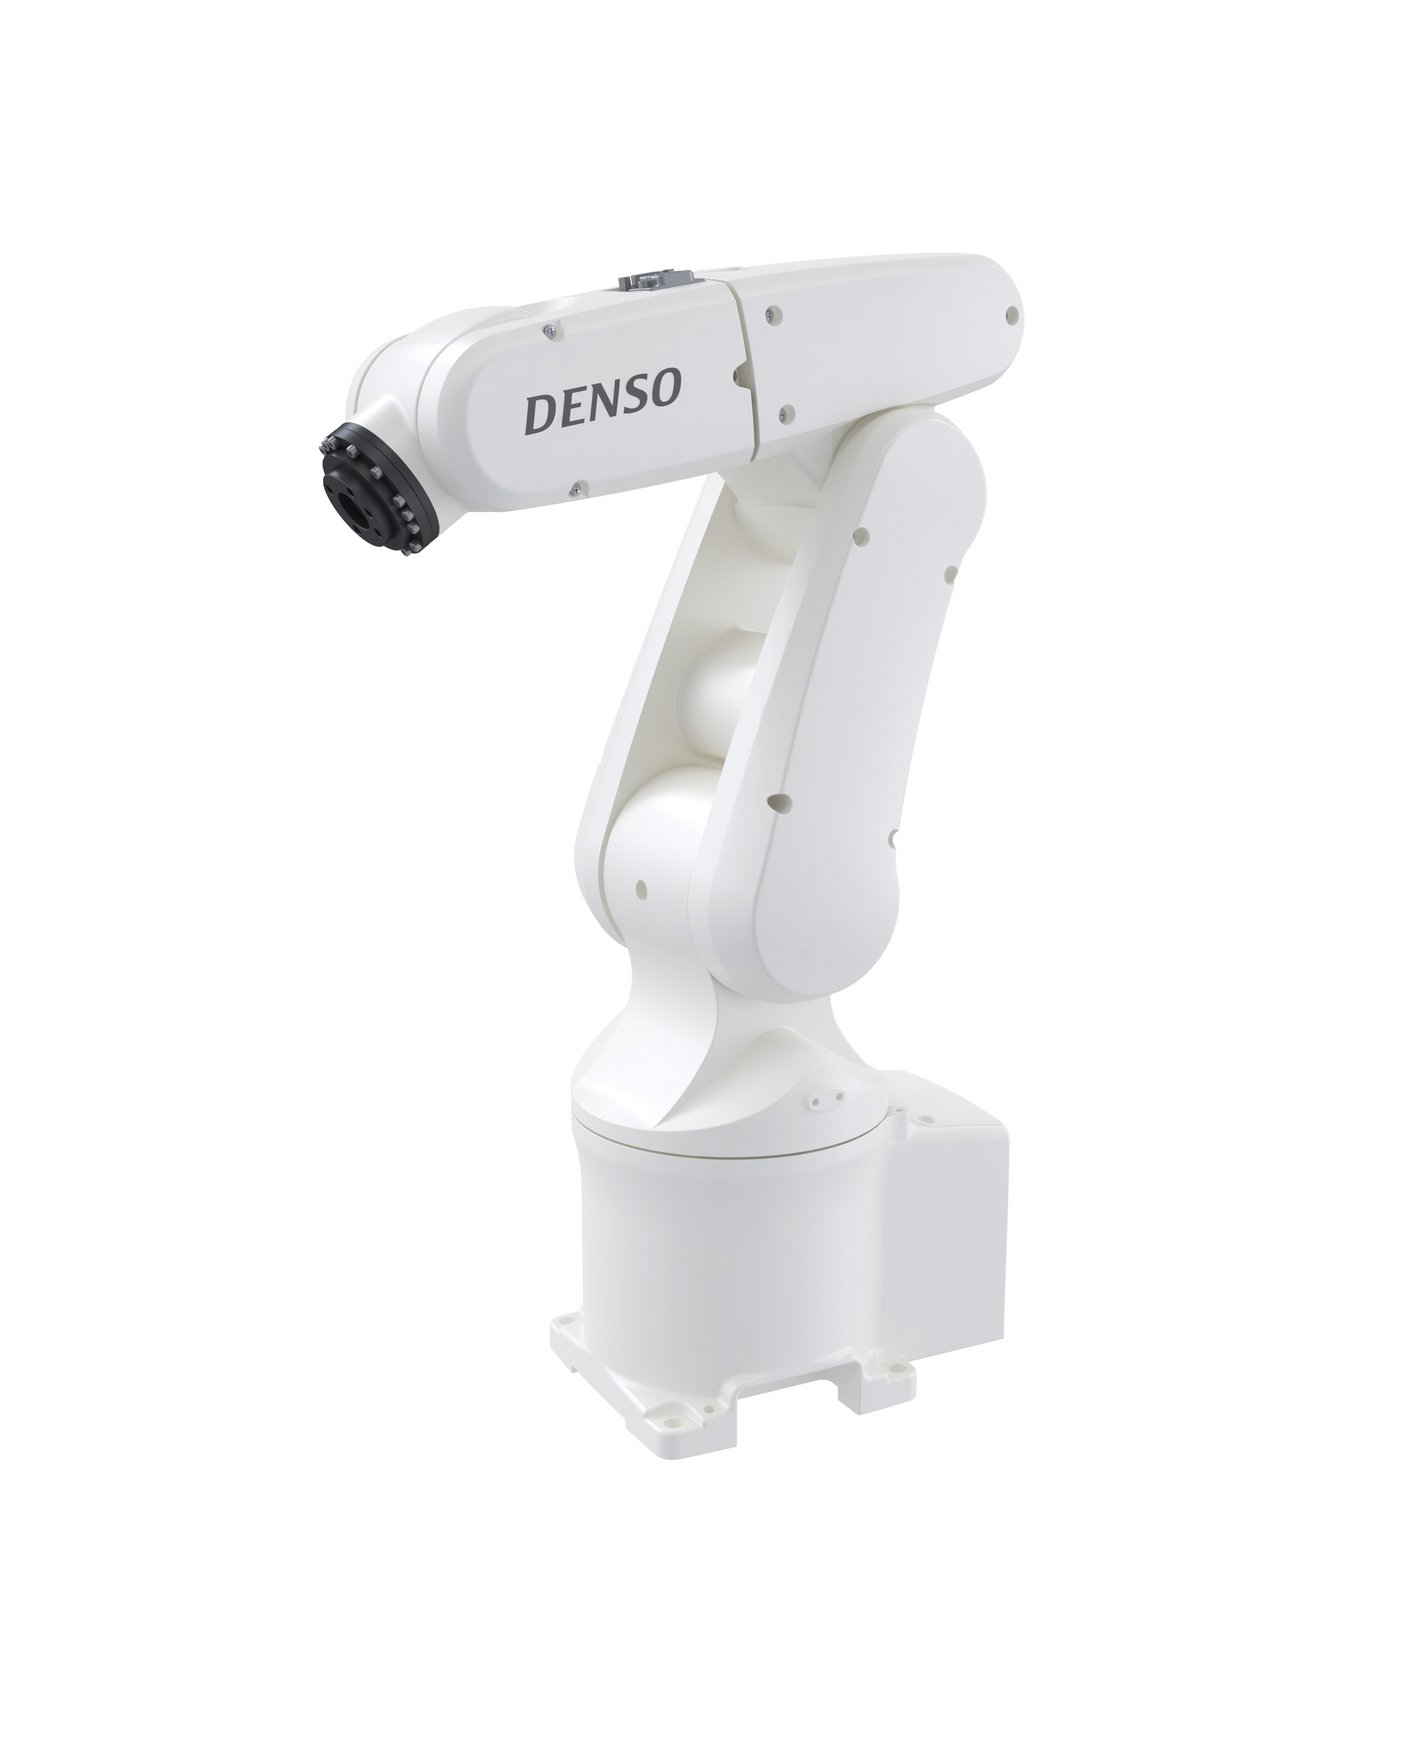
Available in 5- and 6-axis configurations, the VP Series robots are the most compact of all DENSO robots and are perfect for installation where motion space is limited.
Improved high-speed motion results in more cycles per minute (CPM) and therefore higher productivity.
Flexible Mounting Configuration
The HSR robot is available in both floor- and ceiling-mount models.
Optimum Layout
A large-capacity motor is integrated into the base unit. Weight reduction of the arm and an optimized arm design allow the robot to achieve its continuous high-speed performance.
Model name
VP-5243
VP-6242
No. of axes
5
6
Position detection
Absolute encoder
Absolute encoder
Drive motor
AC servomotors for all joints
AC servomotors for all joints
Brakes
Brakes for all joints
Brakes for all joints
Overall arm length (first arm+second arm)
430mm (210mm+22mm)
420mm (210mm+210mm)
Arm offset
J3 (front arm)
–
75mm
Maximum motion area (Point P)
430mm
432mm
Motion range
J1
±160°
±160°
J2
±120°
±120°
J3
+136°, -128°
+160°, +19°
J4
–
±160°
J5
±120°
±120°
J6
±360°
±360°
Maximum payload (wrist downward movement is within ±45°)
3kg *3
2.5kg *4
Maximum composite speed (at the center of an end-effector mounting face)
3,900mm/sec
–
Cycle time *1
0.99 sec
–
Position repeatability at the center of an end-effector mounting face *2
±0.02mm
–
Maximum allowable inertia moment (interia)
J4, J5
0.04kgm² *5
0.03kgm²
J6
0.01kgm²
0.007kgm²
User air piping
4 systems (φ4×4)
4 systems (φ4×4)
User signal line
9 (for proximity sensor signals, etc.)
9 (for proximity sensor signals, etc.)
Air source
Operating pressure
0.10 – 0.39 MPa
0.10 – 0.39 MPa
Maximum allowable pressure
0.49 MPa
0.49 MPa
Noise
<80 dB(A)
<80 dB(A)
Approximate weight
13kg
15kg
*1 Time required for a robot to move a 1kg payload between two points 300mm apart at a height of 25mm.
*2 Position repeatability is the precision at constant ambient temperature.
*3 If wrist downward movement exceeds ±45°, the maximum payload is 2.5kg.
*4 If wrist downward movement exceeds ±45°, the maximum payload is 2kg.