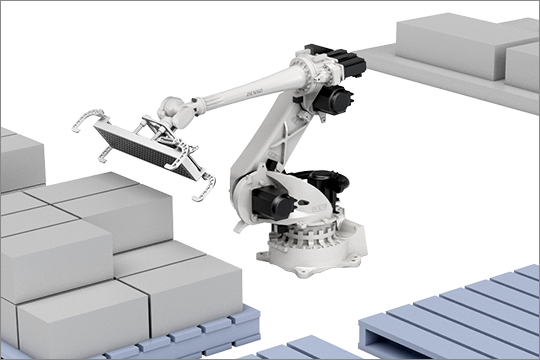
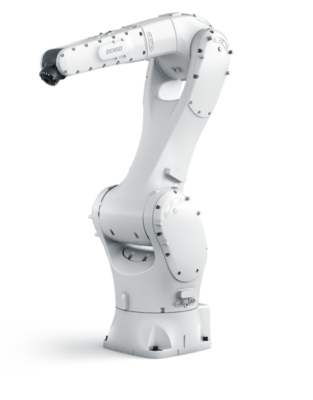
Improved high-speed motion results in more cycles per minute (CPM) and therefore higher productivity.
Flexible Mounting Configuration
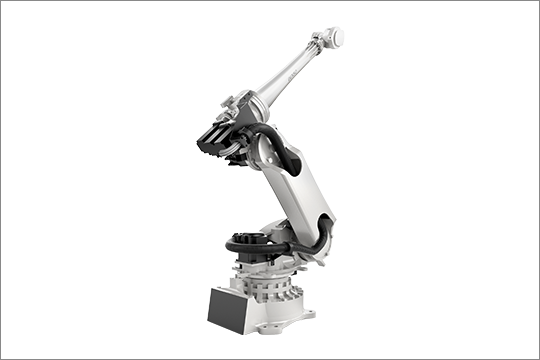
The HSR robot is available in both floor- and ceiling-mount models.
Optimum Layout
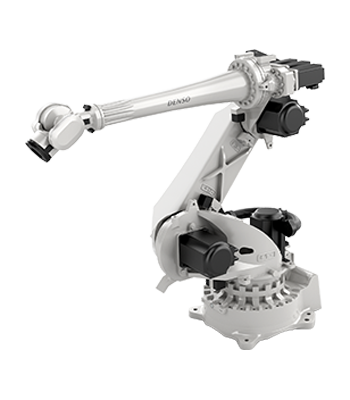
A large-capacity motor is integrated into the base unit. Weight reduction of the arm and an optimized arm design allow the robot to achieve its continuous high-speed performance.
Higher Payload and Longer Arm Reach
Suitable for palletizing, depalletizing, inspection, transportation and packaging by taking advantage of higher payload and longer arm reach.
Model name
VLA-4025
VLA-6022
No. of axes
6
6
Position detection method
Absolute encoder
Absolute encoder
Drive motor and brake
AC servomotors for all axes
AC servomotors for all axes
Brakes
Brakes for all axes
Brakes for all axes
Overall arm length (first arm + second arm)
2,085.5 mm
(860 mm+1,225.5 mm)
1,835.5 mm
(860 mm+975.5 mm)
Arm off set
J1 (rotation)
400mm
400mm
J3 (forearm)
210mm
210mm
Maximum arm reach
2,503mm
2,257mm
Motion range *1
J1
±180°*2
±180°*2
J2
-60°, +125°
-60°, +125°
J3
-165°, 0°
-165°, 0°
J4
±2,700° *4
±2,700° *4
J5
±123°
±123°
J6
±2,700° *4
±2,700° *4
Maximum payload
40kg
60kg
Maximum joint speed
J1
170°/s
170°/s
J2
150°/s
150°/s
J3
165°/s
165°/s
J4
265°/s
265°/s
J5
250°/s
249°/s
J6
340°/s
339°/s
Position repeatability
±0.06mm
±0.06mm
Allowable wrist load moment
J4
167 N•m
221 N•m
J5
167 N•m
221 N•m
J6
98 N•m
118 N•m
User air piping
1 system (inner diameter: φ12.5)
1 system (inner diameter: φ12.5)
User signal line(s)
14 (19-core connector)
14 (19-core connector)
15 (17-core connector) *3
15 (17-core connector) *3
Air source
Maximum allowable pressure
2 MPa
2 MPa
IP classification
Unit: IP65, Wrist: IP67
Unit: IP65, Wrist: IP67
Noise
<75 dB(A)
<75 dB(A)
Approximate weight
655kg
645kg
*1 For positive/negative direction, refer to the external dimensions and operating range diagram.
*2 The operating angle is limited when the robot is installed at an angle.
*3 Can be used as Profi Bus/DeviceNet/Profi Net using wiring.