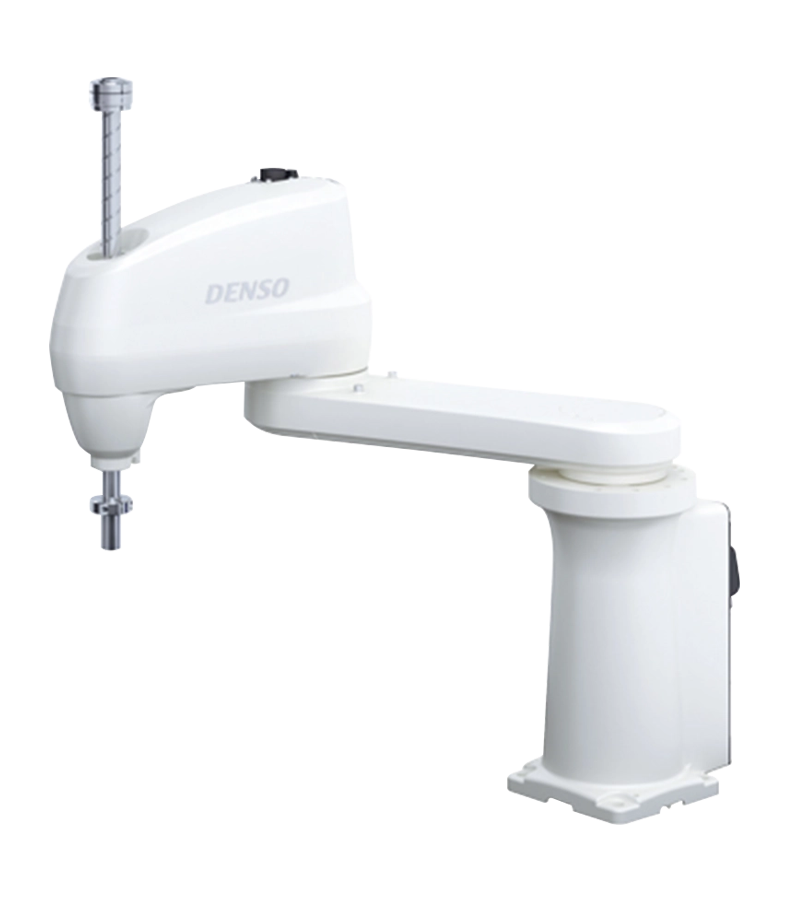
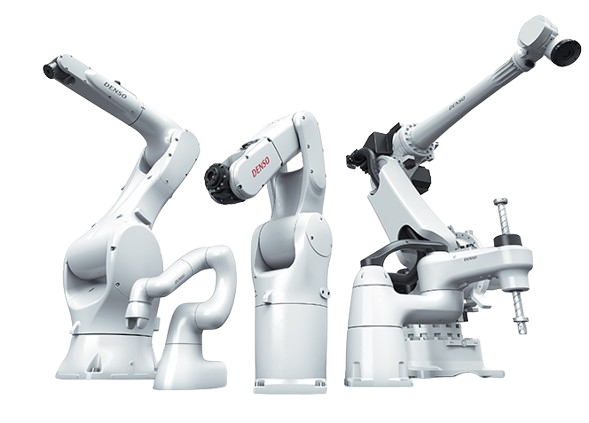
The HS-A1 Series compact, 4-axis SCARA robots offer the highest speed and repeatability in their class. Although these small industrial robots have a compact, space-saving design, they have a large load-handling capability, with a maximum payload of 5 kg. In addition, their large, 0.1 kgm2 maximum allowable moment of inertia enables a wide range of end effectors and applications. All HS-A1 Series robots are available in dust- and mist-proof (IP65) or ISO 4 (class 10) cleanroom configurations.
Improved high-speed motion results in more cycles per minute (CPM) and therefore higher productivity.
Flexible Mounting Configuration
The HSR robot is available in both floor- and ceiling-mount models.
Optimum Layout
A large-capacity motor is integrated into the base unit. Weight reduction of the arm and an optimized arm design allow the robot to achieve its continuous high-speed performance.
Model name *2
HS035A1-N/*
HS045A1-N/*
HS055A1-N/*
No. of axes
4
4
4
Position detection
Absolute encoder
Absolute encoder
Absolute encoder
Drive motor
AC servomotors for all joints
AC servomotors for all joints
AC servomotors for all joints
Brakes
Brakes for Z axis and T axis
Brakes for Z axis and T axis
Brakes for Z axis and T axis
Overall arm length (first arm+second arm)
350mm (125mm+225mm)
450mm (225mm+225mm)
550mm (325mm+225mm)
Motion angle and stroke
J1 (1st Axis)
±155°
±155°
±155°
J2 (2nd Axis)
±145°
±145°
±145°
Z (3rd Axis) *
*10: 100mm *15: 150mm *20: 200mm *32: 320mm
*10: 100mm *15: 150mm *20: 200mm *32: 320mm
*10: 100mm *15: 150mm *20: 200mm *32: 320mm
T (4th Axis)
±360°
±360°
±360°
Maximum payload
5kg
5kg
5kg
Maximum composite speed (at the center of an end-effector mounting face)
7,200mm/sec
6,300mm/sec
7,100mm/sec
Z
2,000mm/sec
2,000mm/sec
2,000mm/sec
T
2,400°/sec
2,400°/sec
2,400°/sec
Cycle time *3
0.29 sec
0.29 sec
0.29 sec
Position repeatability(at the center of an end-effector mounting face) *4
J1+J2
±0.015mm
±0.02mm
±0.02mm
Z
±0.01mm
±0.01mm
±0.01mm
T
±0.005°
±0.005°
±0.005°
Maximum force-fit
98N (1 sec or less)
98N (1 sec or less)
98N (1 sec or less)
Maximum allowable inertia moment (inertia)
0.1kgm²
0.1kgm²
0.1kgm²
User air piping
4 systems (φ4×2, φ6×2)
4 systems (φ4×2, φ6×2)
4 systems (φ4×2, φ6×2)
User signal line
19 (for proximity sensor signals, etc.)
19 (for proximity sensor signals, etc.)
19 (for proximity sensor signals, etc.)
Air source
Operating pressure
0.05 – 0.35 MPa
0.05 – 0.35 MPa
0.05 – 0.35 MPa
Maximum allowable pressure
0.59 MPa
0.59 MPa
0.59 MPa
Noise
<80 dB(A)
<80 dB(A)
<80 dB(A)
IP classification
IP65 (Option)
IP65 (Option)
IP65 (Option)
Cleanroom classification
Class 3 (Option)
Class 3 (Option)
Class 3 (Option)
Approximate weight
25kg
25kg
25kg
*
The data listed on this page is for standard models. For other options, please contact us here.
*2 An asterisk [*] in a model name indicates Z-axis stroke.
*3 Time required for a robot to move a 2kg payload between two points 300mm apart at a height of 25mm.
*4 Position repeatability is the precision at constant ambient temperature.