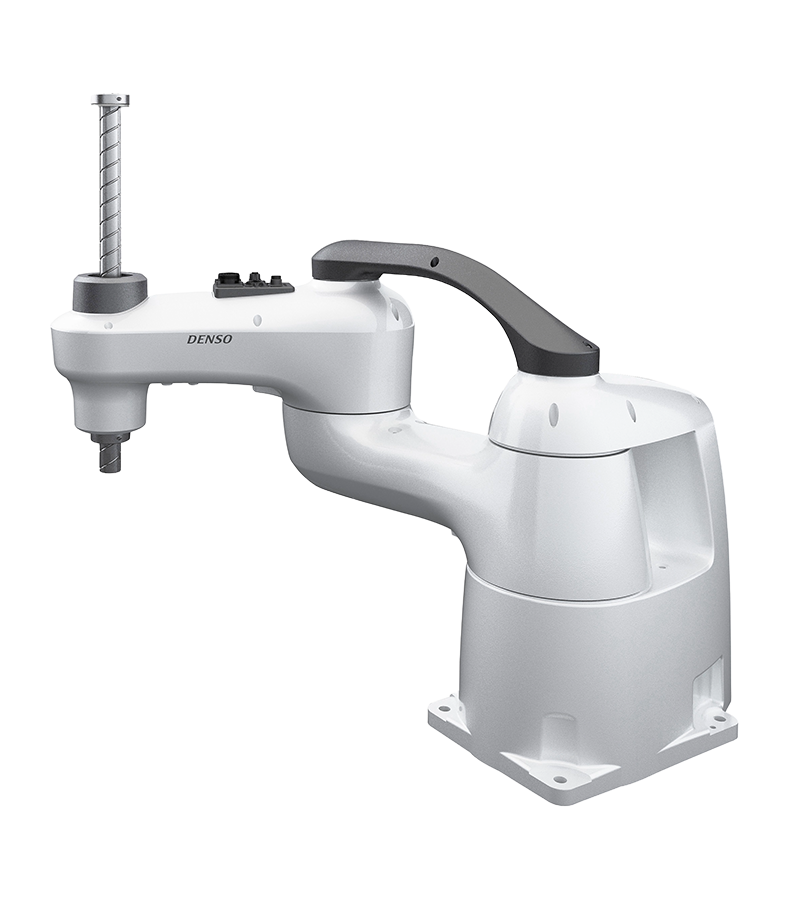
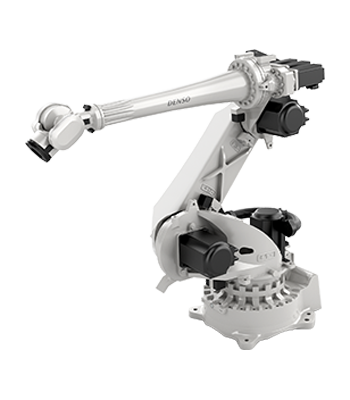
| Model name | HSR048A1-N/S* | HSR055A1-N/S* | HSR065A1-N/S* |
| No. of axes | 4 | 4 | 4 |
| Position detection | Absolute encoder | Absolute encoder | Absolute encoder |
| Drive motor | AC servomotors for all axes | AC servomotors for all axes | AC servomotors for all axes |
| Brakes | Brakes for Z and T axes | Brakes for Z and T axes | Brakes for Z and T axes |
| Overall arm length (first arm+second arm) | 480mm
(205mm+275mm) | 550mm
(275mm+275mm) | 650mm
(375mm+275mm |
| Motion angle and stroke | J1 (1st Axis) | ±130° | ±130° | ±130° |
| J2 (2nd Axis) | ±143.5° | ±150° | ±150° |
| Z (3rd Axis) * | *10: 100mm
*20: 200mm
*32: 320mm
*51: 510mm | *10: 100mm
*20: 200mm
*32: 320mm
*51: 510mm | *10: 100mm
*20: 200mm
*32: 320mm
*51: 510mm |
| T (4th Axis) | ±360° | ±360° | ±360° |
| Axis combination | J1 + J2 + Z + T | J1 + J2 + Z + T | J1 + J2 + Z + T |
| Maximum payload | Z and T | 8kg | 8kg | 8kg |
| Maximum composite speed | At the center of the hand mounting flange | 7,540mm/s | 8,000mm/s | 8,850mm/s |
| Z | 100mm: 1,700mm/s
200mm: 2,300mm/s
320mm: 2,475mm/s | 100mm: 1,700mm/s
200mm: 2,300mm/s
320mm: 2,475mm/s | 100mm: 1,700mm/s
200mm: 2,300mm/s
320mm: 2,475mm/s |
| T | 2,500°/s | 2,500°/s | 2,500°/s |
| Position repeatability (value at the constant ambient temperature.) | J1+J2 | ±0.01mm | ±0.012mm |
| Z | ±0.01mm | ±0.01mm | ±0.01mm |
| T | ±0.004° | ±0.004° | ±0.004° |
| Maximum force-fit | 98N (1 sec or less) | 98N (1 sec or less) | 98N (1 sec or less) |
| Maximum allowable inertia moment | 0.12kgm² | 0.12kgm² | 0.12kgm² |
| Brake releasing | Models except UL-Listed ones | 1. Press the brake release switch in the direct teaching mode.
2. Enter a brake release command with the teach pendant or mini-pendant. | 1. Press the brake release switch in the direct teaching mode.
2. Enter a brake release command with the teach pendant or mini-pendant. | 1. Press the brake release switch in the direct teaching mode.
2. Enter a brake release command with the teach pendant or mini-pendant. |
| UL-Listed models | 1. Press the brake release switch when the controller power is ON.
2. The teach pendant or mini-pendant cannot release the brakes. | 1. Press the brake release switch when the controller power is ON.
2. The teach pendant or mini-pendant cannot release the brakes. | 1. Press the brake release switch when the controller power is ON.
2. The teach pendant or mini-pendant cannot release the brakes. |
| User air piping | 4 systems (φ4×2, φ6×2) | 4 systems (φ4×2, φ6×2) | 4 systems (φ4×2, φ6×2) |
| User signal lines | ・19 (for proximity sensor signals, etc.)
・Ethernet (8) *1 | ・19 (for proximity sensor signals, etc.)
・Ethernet (8) *1 | ・19 (for proximity sensor signals, etc.)
・Ethernet (8) *1 |
| Air source | Operating pressure | 0.05 – 0.35 MPa | 0.05 – 0.35 MPa | 0.05 – 0.35 MPa |
| Max. allowable pressure | 0.59 MPa | 0.59 MPa | 0.59 MPa |
| Noise | <80 dB(A) | <80 dB(A) | <80 dB(A) |
| Approximate weight *2 | 31kg | 31.5kg | 32kg |