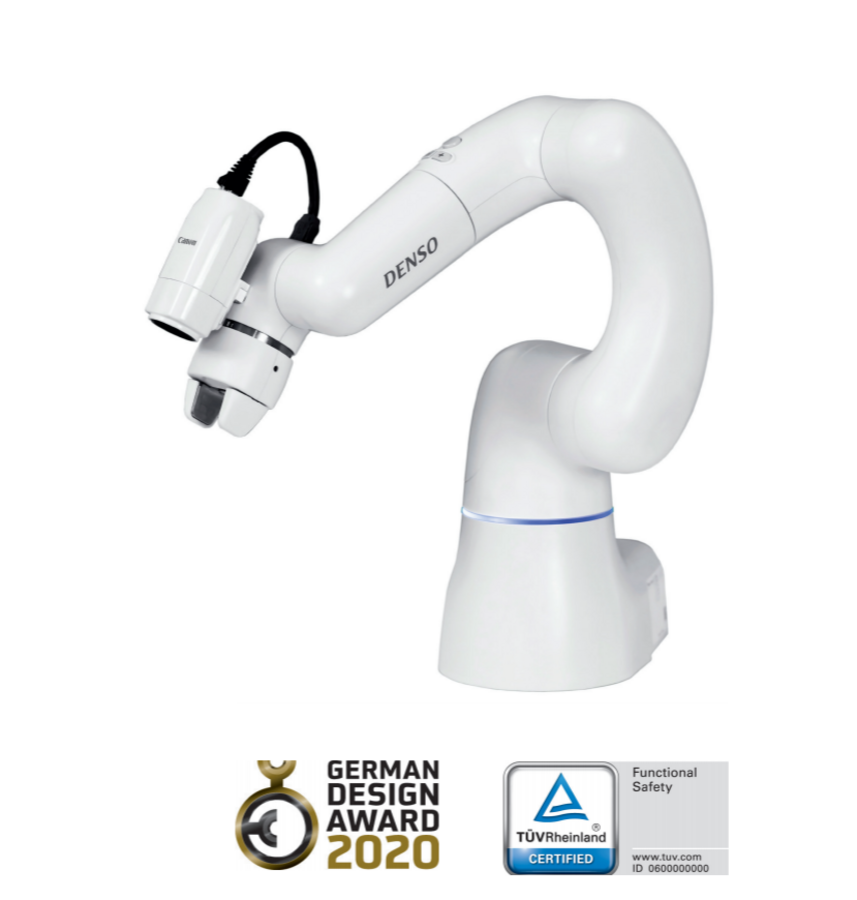
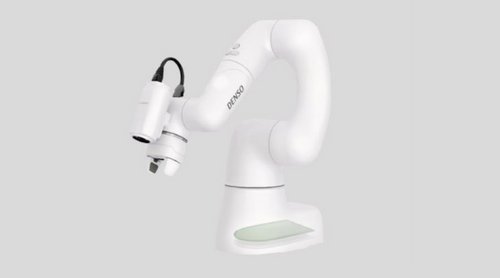
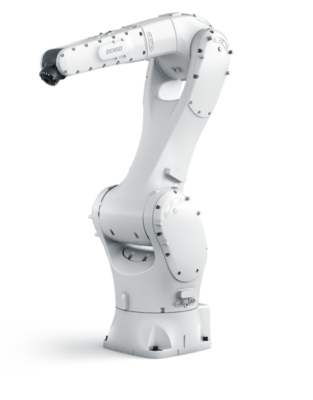
Introducing the all-new COBOTTA, a human-friendly, compact, and collaborative six-axis robot you can take anywhere and automate tasks right away. No expert knowledge is required, making operation quick and simple. Do you need that extra hand? Do you want to leave basic and repetitive tasks to robots and make more time for more complex work? COBOTTA will open infinite possibilities to address your needs and realize creative, new ideas.
Collaborative robots do not require safety fences. The unique outer contour has no sharp edges, and consists of curves that prevent hands from getting caught. Sensors are built into the six moving parts for constant monitoring of speed and torque
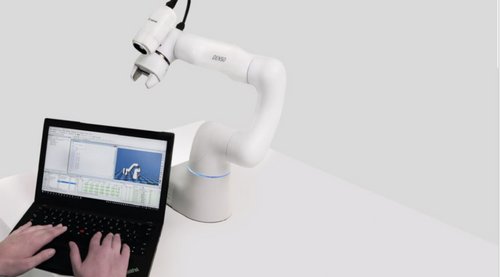
The integrated controller is open, and COBOTTA’s control API is made public, allowing creators to develop their own applications in the environment they choose (055 version)
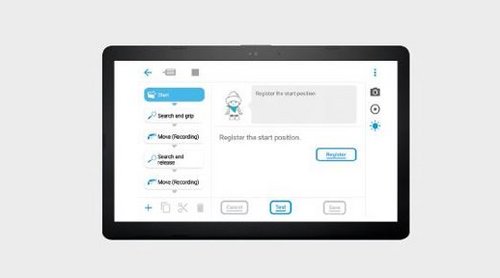
Easy programming with tablet based App Cobotta World.
Set up a new program within minutes, Teach COBOTTA by moving it directly and selecting tasks from the preset job items
Builtin Controller
Robot arm weight with controller only 4 kg
Small space needed: approx. 200cm²
Easy transportation
Ext. Communication: Ethernet TCP/ IP, 2 x USB, Field Network: EtherCAT, ProfiNET, EtherNet IP External I/ O: 20 Input/ 20 Output
Extra features
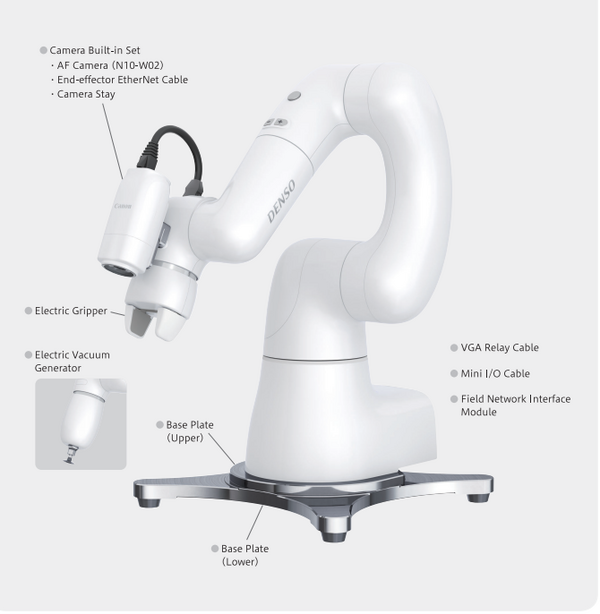
Thanks to the fully integrated, built-in electrical gripper and a built-in A/F camera in the robot arm, combined with the standard programming Apps, users can easily create force-controlled gripper applications as well as other applications in just a few minutes. This also enables 2D image recognition.
0.5kg (0.7 kg within ±10 degrees with the wrist angled downward) *2
Position repeatability
±0.05mm *3
Maximum composite speed (center of tool mounting face)
4.32sec in the factory configuration, 1.6sec when set to maximum speed (Reciprocating movement time for 200mm in the horizontal direction and 25mm in the vertical direction)
Software
Standard version: COBOTTA-dedicated software OSS version: None (*Linux, etc. may be installed by the customer)