Overview
- Fast performer
- Safety Design
- Easy to use with an open platform
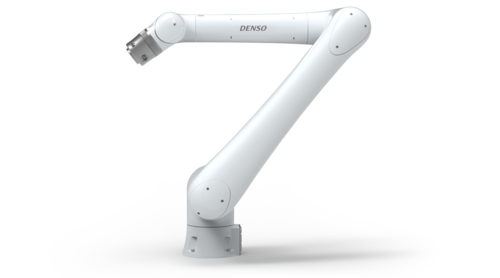
A high-speed collaborative robot engineered for productivity and safety
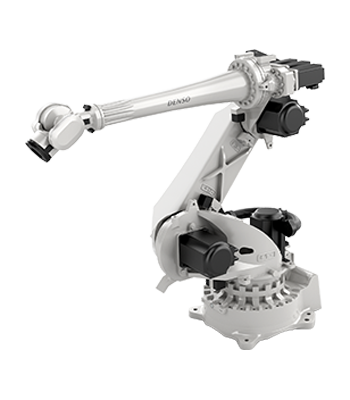
The COBOTTA PRO is designed not only to facilitate collaboration between human workers and robots but also to consistently maximize productivity. It delivers a blend of productivity and safety for both simple tasks and multi-step processes like assembly and inspection work.
Top-class speed
With a top TCP* speed of 2.500 mm/s, the COBOTTA PRO is one of the fastest collaborative robots in the industry. Its speed is on par with that of a 5-and 6-axis robot during high-speed operation. Acceleration increases by mounting a proprietary, high-rigidity torque sensor on its lightweight, slim arm axes.
Fine direct teaching
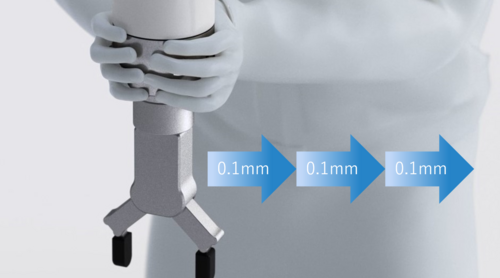
The inching function enables precise teaching on the order of 0.1 mm by letting you move the arm by the specified unit of distance. Since you can perform fine adjustments using direct teaching alone, you can realize intuitive teaching for elaborate tasks like mating and insertion of parts. The plane alignment function automatically moves in the vertical direction relative to a plane configured in advance by three-point teaching. It simplifies the process of setting up diagonal vertical movements, helping make teaching part insertion and assembly tasks less labor- and time-intensive.
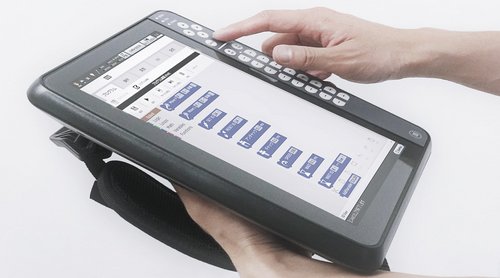
Simple, intuitive programming
By using BLOCKLY, a visual intuitive programming language, even beginners can create advanced robot applications, while avoiding any syntax errors. Simple drag-and-drop operation by connect blocks from a library. Original icons make it easy to visually identify operations, ensuring the system can be learned quickly. Even beginners can create programs in a short period of time.
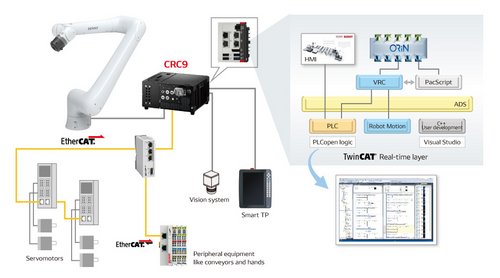
Integrated Controller
The COBOTTA PRO supports the CRC9, based on the RC9 robot controller. Like the RC9, the CRC9 provides integrated equipment control and an integrated development environment. In addition, it can be combined with 2D/3D vision as well as general-purpose AI software to automate manual tasks that would be highly difficult to accommodate using conventional methods
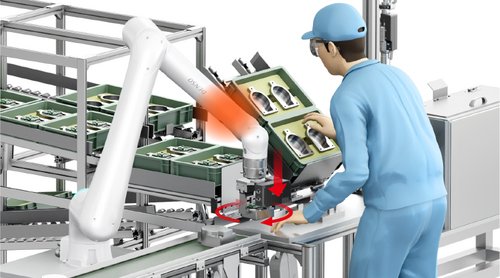
Built-in Torque Sensors
The arm incorporates a force sensor, allowing a more compact design for the hand and surrounding hardware. Force control is possible with the compliance function and a force sensor.
| Model name | COBOTTA PRO 900 | COBOTTA PRO 1300 | |
| No. of axes | 6 | 6 | |
| Position detection | Absolute encoder | Absolute encoder | |
| Drive motor | AC servo motors for all axes | AC servo motors for all axes | |
| Brakes | Brakes for all axes | Brakes for all axes | |
| Overall arm length (first arm+second arm) | 900mm | 1,300mm | |
| Maximum motion area (Point P: 4th, 5th, 6th axis center) | 908mm | 1,304mm | |
| Maximum arm reach | 1,066mm | 1,463mm | |
| Maximum motion angle | 1st axis | ±270° | ±270° |
| 2nd axis | ±150° | ±150° | |
| 3rd axis | ±150° | ±150° | |
| 4th axis | ±270° | ±270° | |
| 5th axis | ±150° | ±150° | |
| 6th axis | ±360° | ±360° | |
| Maximum payload | 6kg | 12kg | |
| Maximum speed in a collaborative state | Without touch-sensing soft cover | 1,800mm/s | 1,800mm/s |
| With touch-sensing soft cover (optional) | 2,000mm/s | 2,000mm/s | |
| Maximum TCP translational speed in a non-collaborative state | 2,100mm/s | 2,500mm/s | |
| Position repeatabilty (at the center of a tool mounting face in each of X, Y and Z directions *1 | ±0.03mm | ±0.04mm | |
| Maximum allowable moment | Around 4th axis | 20 N•m | 38.5 N•m |
| Around 5th axis | 14.6 N•m | 28 N•m | |
| Around 6th axis | 6.5 N•m | 12 N•m | |
| Maximum allowable moment of inertia | Around 4th axis | 0.8kgm² | 1.45kgm² |
| Around 5th axis | 0.45kgm² | 0.9kgm² | |
| Around 6th axis | 0.1kgm² | 0.35kgm² | |
| Connector panel mounting position | Back side of the robot base (bottom side of the robot base is optional) | Back side of the robot base (bottom side of the robot base is optional) | |
| Equipment for Tool | Signal line: 2 pins (for Air Piping type), | Signal line: 2 pins (for Air Piping type), | |
| 8 pins (for Through Wiring type) *2 | 8 pins (for Through Wiring type) *2 | ||
| Ethernet cable: 1 cable (8 pins) *3 | Ethernet cable: 1 cable (8 pins) *3 | ||
| Analog input: 2 systems RS-485: 1 system | Analog input: 2 systems RS-485: 1 system | ||
| Hand input: 5 pins / Hand output: 5 pins | Hand input: 5 pins / Hand output: 5 pins | ||
| Lighting: 1 system | Lighting: 1 system | ||
| Power source + (switching between OFF, 12 V and 24 V), Power source – (0 V) | Power source + (switching between OFF, 12 V and 24 V), Power source – (0 V) | ||
| Air piping for user | φ4×2 (for Air Piping type) | φ4×2 (for Air Piping type) | |
| Environment conditions of installation site (during operation) | Without touch-sensing soft cover | Ambient temperature:0 to 50° C | Ambient temperature:0 to 50° C |
| With touch-sensing soft cover (optional) | Ambient temperature:5 to 45° C | Ambient temperature:5 to 45° C | |
| Relative Humidity: 20 to 90% (No dew condensation allowed.) Vibration: <4.9m/s² (0.5G) | Relative Humidity: 20 to 90% (No dew condensation allowed.) Vibration: <4.9m/s² (0.5G) | ||
| Pollution degree (IEC 60664-1) | 3 | 3 | |
| Applicable standards | ISO 10218-1:2011 | ISO 10218-1:2011 | |
| ISO 13849-1:2015 | ISO 13849-1:2015 | ||
| ISO/TS 15066:2016 | ISO/TS 15066:2016 | ||
| IEC 60204-1:2016/A1:2021 | IEC 60204-1:2016/A1:2021 | ||
| EN 61000-6-2:2005 | EN 61000-6-2:2005 | ||
| EN 61000-6-4:2007/A1:2011 | EN 61000-6-4:2007/A1:2011 | ||
| EN 61000-6-7:2015 | EN 61000-6-7:2015 | ||
| Air source | Operating pressure | 0 – 0.39 MPa | 0 – 0.39 MPa |
| Maximum allowable pressure | 0.49 Mpa | 0.49 Mpa | |
| Noise | <65 dB(A) | <65 dB(A) | |
| IP classification | IP54 | IP54 | |
| Cleanroom classification (ISO14644-1) | Class 5 | Class 5 | |
| Approximate weight | 29kg | 41kg | |
| *1 Precision figures assume use at a constant ambient temperature. | |||
| *2 Choose either the air piping type or the through wiring type. | |||
| *3 The Ethernet cable connected to the connector panel must be 20m or less in length. | |||